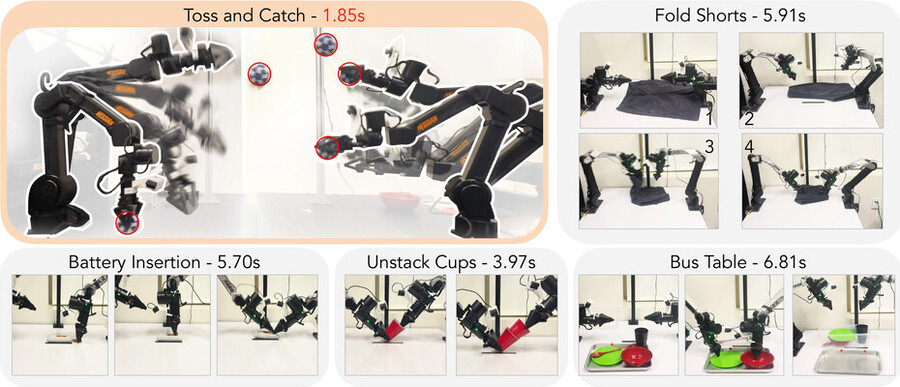
ALOHA Lightning: Learning Fast and Precise Manipulation
ICRA 2026
A full-stack system for learning fast, precise bimanual manipulation from near-human-speed kinesthetic demonstrations.
CV | Email | Github | Google Scholar | LinkedIn
I am a Research Assistant in the IRIS Lab at Stanford University, advised by Chelsea Finn. Previously, I worked with Zipeng Fu. Recently, I completed my Master's degree at the University of Amsterdam, and before that I graduated from Imperial College London.
I'm interested in high speed robot learning, contact-rich manipulation, and practical solutions to accelerating robot learning research.
ICRA 2026
A full-stack system for learning fast, precise bimanual manipulation from near-human-speed kinesthetic demonstrations.